Ros Package Template
The package was developed by charles river analytics, inc. Robot_localization is a package of nonlinear state estimation nodes. To open a rosbuild ros package code as a project, use open file or project and select the cmakelists.txt of your ros package. We would like to show you a description here but the site won’t allow us. Please refer directly to ros wiki.;
Ros Package Template - The package was developed by charles river analytics, inc. To open a rosbuild ros package code as a project, use open file or project and select the cmakelists.txt of your ros package. We would like to show you a description here but the site won’t allow us. A ros driver for orbbec 3d cameras. This package supports ros kinetic, melodic and noetic distributions. Please refer directly to ros wiki.; Robot_localization is a package of nonlinear state estimation nodes. This tutorial introduces ros graph concepts and discusses the use of roscore, rosnode, and rosrun. Please ask questions on answers.ros.org. The template could for example contain the license header, author name, and include guards (in case of a header file).
Ros Package Template Gallery
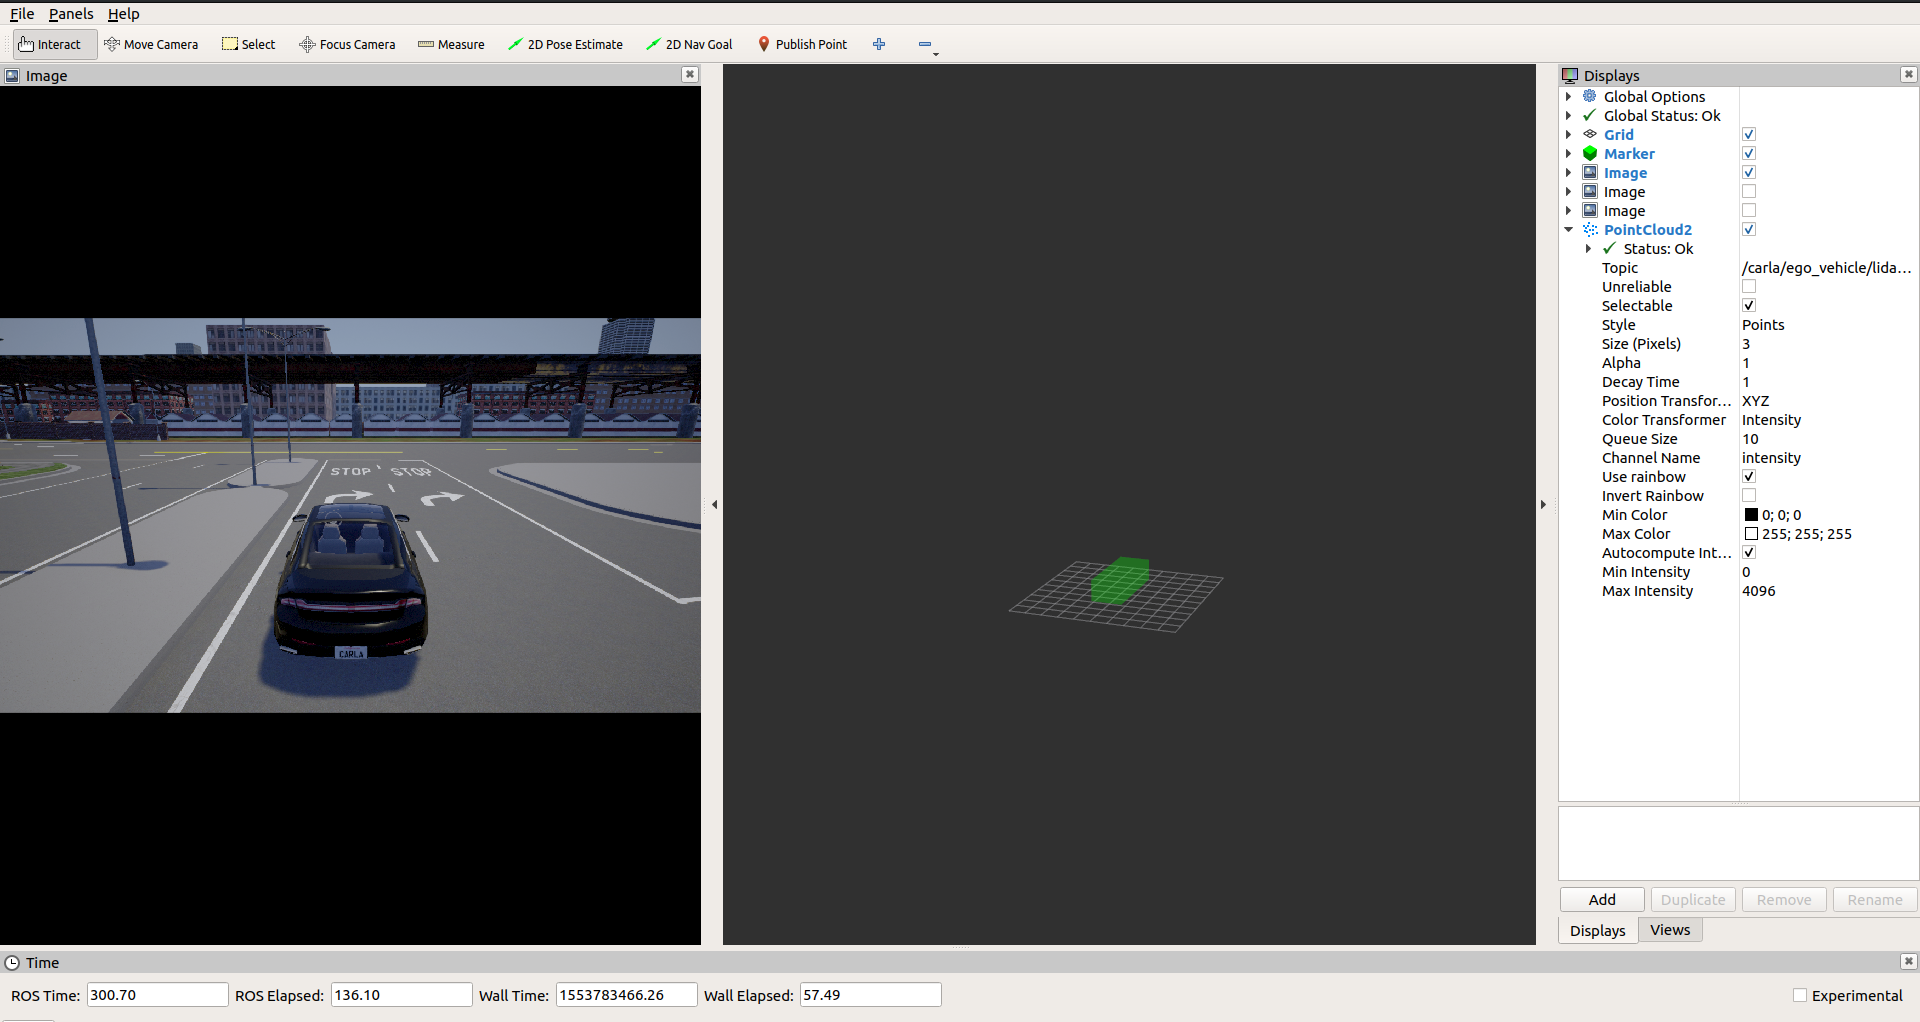
ROSCARLA Integration > How to use ROS Bridge package
Please refer directly to ros wiki.; This tutorial covers the toolchain to build a package..
Wedding Invitation 1041 SAMPLE. Modern invitation template.
This tutorial covers the toolchain to build a package. The package was developed by charles.
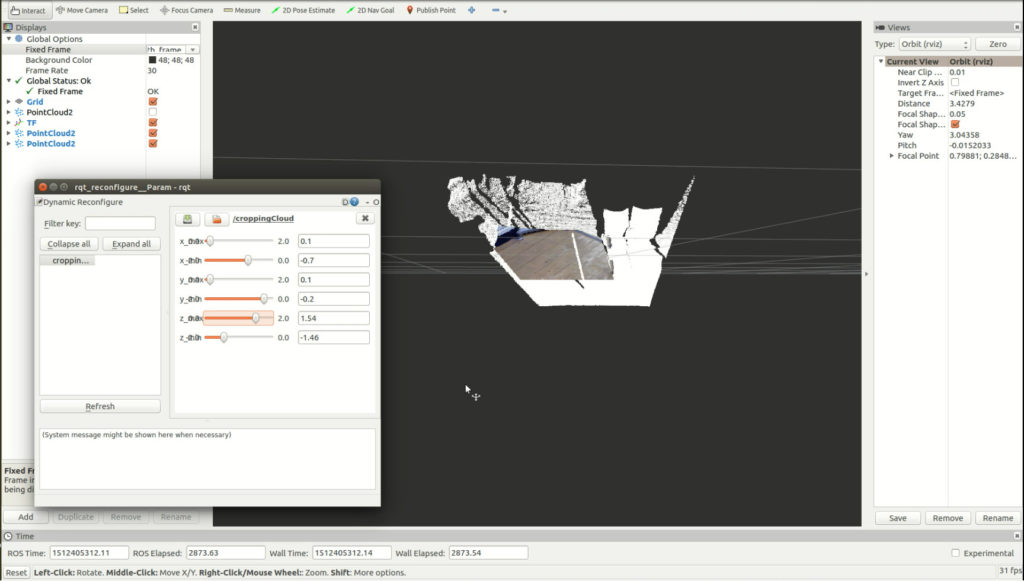
A GUI ROSpackage for cropping pcl pointcloud with dynamic reconfigure
We would like to show you a description here but the site won’t allow us..
[Tutorial] How to build a GUI in ROS with Qt / C++? CasperWin 博客园
Robot_localization is a package of nonlinear state estimation nodes. This package supports ros kinetic, melodic.
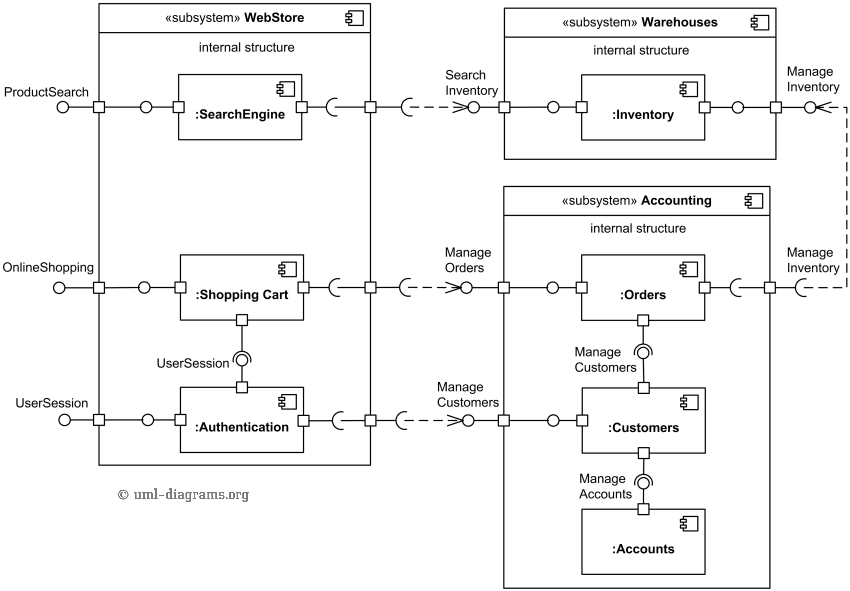
Contoh Interface Database Contoh Ros
Please refer directly to ros wiki.; Please ask questions on answers.ros.org. Robot_localization is a package.
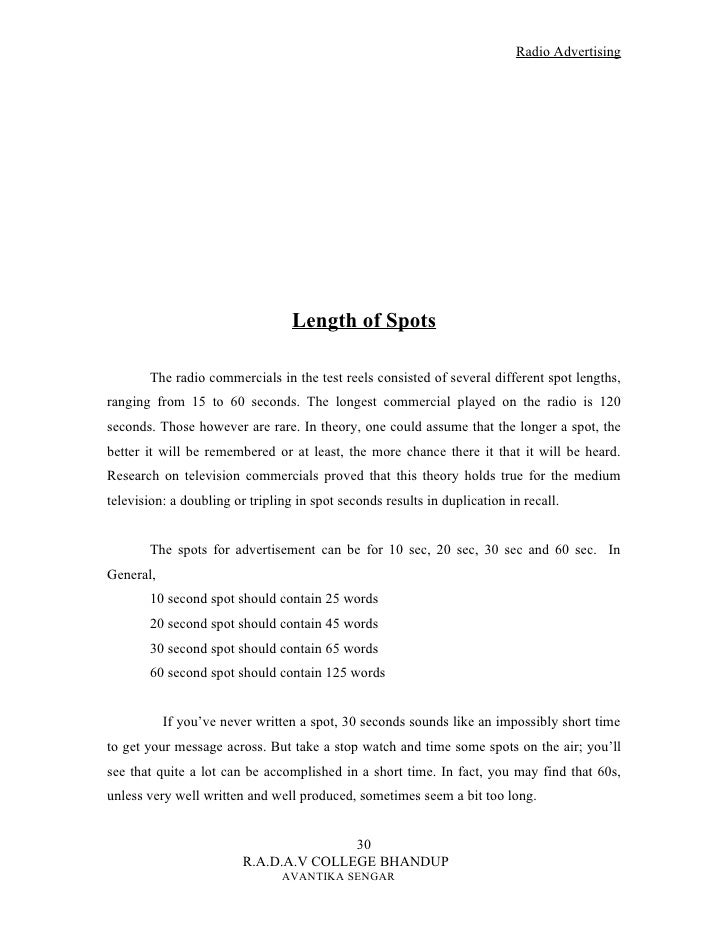
Radio advertising
The package was developed by charles river analytics, inc. A ros driver for orbbec 3d.

ROS put out a package pickup reminder for their residents Take this
Please refer directly to ros wiki.; We would like to show you a description here.
Overleaf Beamer Template Metropolis The Best Picture Of Beam
This tutorial covers the toolchain to build a package. The template could for example contain.
A ros driver for orbbec 3d cameras. To open a rosbuild ros package code as a project, use open file or project and select the cmakelists.txt of your ros package. Please refer directly to ros wiki.; We would like to show you a description here but the site won’t allow us. This tutorial introduces ros graph concepts and discusses the use of roscore, rosnode, and rosrun. This tutorial covers the toolchain to build a package. This package supports ros kinetic, melodic and noetic distributions. The package was developed by charles river analytics, inc. Robot_localization is a package of nonlinear state estimation nodes. Please ask questions on answers.ros.org. The template could for example contain the license header, author name, and include guards (in case of a header file).
We Would Like To Show You A Description Here But The Site Won’t Allow Us.
The package was developed by charles river analytics, inc. Please ask questions on answers.ros.org. Please refer directly to ros wiki.; To open a rosbuild ros package code as a project, use open file or project and select the cmakelists.txt of your ros package.